Robot joints and actuation
quasi-direct-drive actuator: 9 N·m rated / 22 N·m peak at 9:1; 0.51 N·m back-drive torque — backdrivable for legged / contact-rich joints.
Engineering inference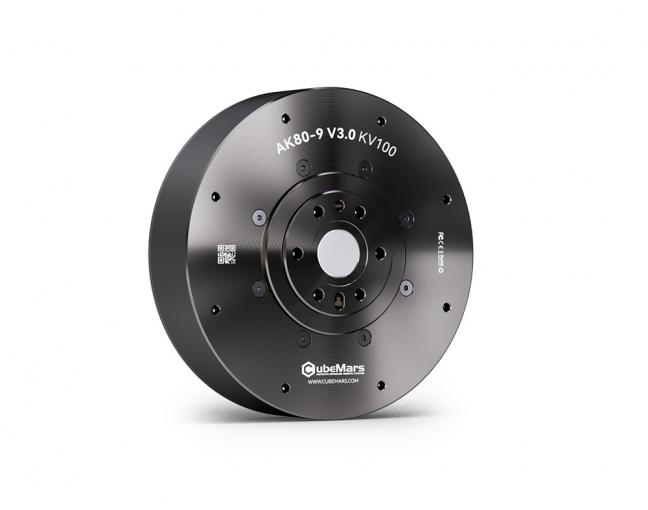
CubeMars
CubeMars AK80-9 V3.0 KV100 quasi-direct-drive robotic actuator: BLDC motor + 9:1 planetary gearbox + driver + 16-bit magnetic encoder, 9 N·m rated / 22 N·m peak, 570 rpm no-load at 48 V, 15 arcmin backlash, 0.51 N·m back-drive, CAN on XT30 2+2 + UART, Ø98 × 38.5 mm, 490 g.
AK80-9 V3.0 KV100Development boardFacts about the complete product. Unknown values remain open design questions.
Guidance to help you shortlist. The basis is shown for each recommendation.
quasi-direct-drive actuator: 9 N·m rated / 22 N·m peak at 9:1; 0.51 N·m back-drive torque — backdrivable for legged / contact-rich joints.
Engineering inferenceCubeMars lists AGV among the applications (spec grid 'Application' row).
Manufacturer guidanceCAN bus with position, speed, torque and MIT (impedance) modes — the control loops a legged or collaborative joint needs.
Engineering inferenceNo-load speed, rated performance and stall limits describe different operating points. A stall specification is not a continuous operating rating.
Supply range 48–48 V.
From $479.9 at www.cubemars.com. Prices are observed unit prices before tax and shipping.
98 × 98 × 38.5 mm. A STEP model is available for enclosure fit checks.
Every value in this record is traced to a source — 2 documents including the board and chip datasheets — with the page and table cited per value. Unknowns are left explicit, never guessed.