Robot joints and actuation
smart servo: 0.52 N·m peak at 288.4:1, 103 rpm no-load.
Engineering inference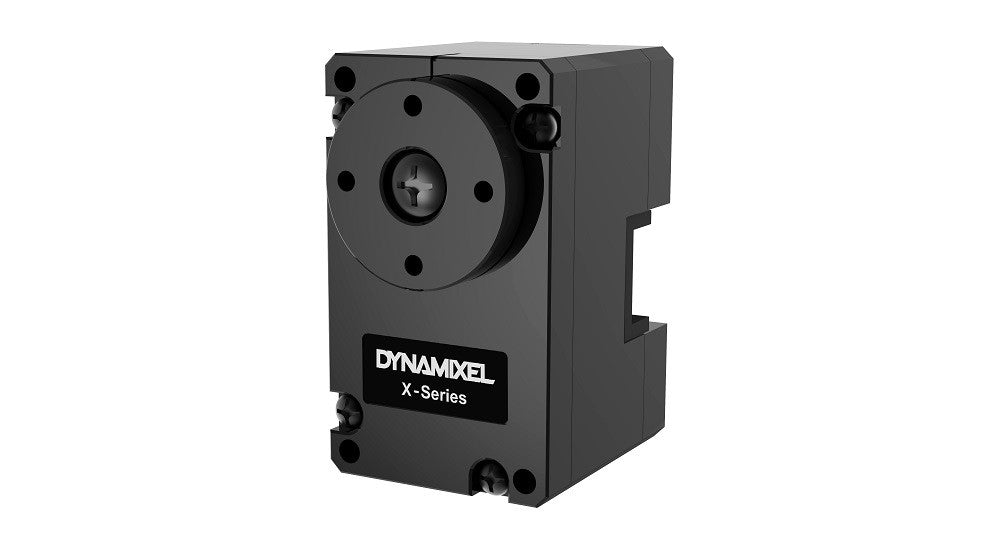
ROBOTIS
ROBOTIS DYNAMIXEL XL330-M077-T smart servo — the fast XL330: cored DC motor + 77.5:1 plastic gearbox + Cortex-M0+ controller + 12-bit AS5601 absolute encoder, 0.215 N·m stall / 383 rpm no-load at 5 V (3.7–6 V), current / velocity / position / multi-turn / PWM modes, TTL bus up to 4 Mbps, 20 × 34 × 26 mm, 18 g. Common in low-cost leader arms and grippers.
XL330-M077-TDevelopment boardFacts about the complete product. Unknown values remain open design questions.
Guidance to help you shortlist. The basis is shown for each recommendation.
smart servo: 0.52 N·m peak at 288.4:1, 103 rpm no-load.
Engineering inferenceTTL bus with current, velocity, position, multi-turn and current-based position modes; 253 IDs on one bus.
Engineering inferenceCurrent (torque) control mode is the ROBOTIS-listed use for grippers and force-sensitive applications; 18 g, 20 × 34 × 26 mm.
Engineering inferenceNo-load speed, rated performance and stall limits describe different operating points. A stall specification is not a continuous operating rating.
Generated from the datasheet's dimensioned drawing and measured against it. Download the STEP to check fit in your own enclosure.
What the joint can deliver and how the controller talks to it.
| Connector | Type |
|---|---|
| ttl | TTL 3-pin JST EH (B3B-EH-A header, EHR-03 housing), 21 AWG |
Rated torque is continuous; peak torque is short-duration. Values with two figures (e.g. 24/48 V) are per supply voltage.
No-load, rated-load and stall figures retain their separate test conditions.
Stall torque and current are not continuous ratings. Check the duty cycle and starting load when choosing the driver and power supply.
Product operating conditions, chip ambient ratings, package case limits and junction maxima remain separate.
Reported product dimensions may exclude protruding components. Unknown height does not establish a complete clearance envelope.
Attached generated geometry is an approximate envelope. A generated outline does not establish an electrically verified PCB footprint.
| ID / type | Pins | Pitch | Notes |
|---|---|---|---|
| ttlTTL 3-pin JST EH (B3B-EH-A header, EHR-03 housing), 21 AWG | 3 | Unknown | — |
Every available field, including details beyond the summaries. Null means the value has not been established.
US / USD is the target market. Observed price and stock are separate from a delivery quote.
US · USD
Observed within the last 24 hours. Confirm the current supplier quote.
Visit supplier (opens in a new tab)Delivery depends on quantity, postal code and shipping method. A dispatch statement such as “ship today” is not an arrival estimate.
Each source keeps its own verification status. Confirm the part revision and file contents before using it in a design.
Manufacturer reference
Manufacturer reference
store og:image for the XL330-M077-T page (series photo)
Generated asset
cad_check passed
Generated envelope geometry may also exist for this record. It does not replace manufacturer CAD or a verified electrical land pattern.
Document provenance, retrieval dates and the field groups supported by each source.
Supports: spec.constraints.electrical.supply_voltage_max_v, spec.constraints.electrical.supply_voltage_min_v, spec.constraints.thermal.operating_temp_max_c, spec.constraints.thermal.operating_temp_min_c, spec.geometry.body_length_mm, spec.geometry.cad.bbox.height_mm, spec.geometry.cad.bbox.length_mm, spec.geometry.cad.bbox.width_mm, spec.geometry.cad.envelope_complete, spec.geometry.cad.mesh_path, spec.geometry.cad.step_path, spec.geometry.cad.verification, spec.geometry.dimensions.height_mm, spec.geometry.dimensions.length_mm, spec.geometry.dimensions.width_mm, spec.geometry.other.weight_g, spec.provides.actuator_type, spec.provides.control_interface, spec.provides.control_modes, spec.provides.encoder, spec.provides.encoder_bits, spec.provides.features, spec.provides.gear_ratio, spec.provides.integrated_driver, spec.provides.kt_nm_per_a, spec.provides.motor_type, spec.provides.no_load_speed_rpm, spec.provides.peak_torque_nm, spec.usage.connectors, spec.usage.pinout, spec.usage.pinout_complete, spec.usage.requirements.other.peak_current_a, spec.usage.requirements.rated_voltage_v
sha256 967898feb737c6cce1009f492f427fafe81ce9cffbdc8fa7187e45e152237392
Supports: offers
Supply range 3.7–6 V.
From $27.49 at robotis.us. Prices are observed unit prices before tax and shipping.
26 × 20 × 34 mm. A STEP model is available for enclosure fit checks.
Every value in this record is traced to a source — 2 documents including the board and chip datasheets — with the page and table cited per value. Unknowns are left explicit, never guessed.