Robot joints and actuation
quasi-direct-drive actuator: 7.5 N·m rated / 22 N·m peak at 8:1, 320 rpm no-load.
Engineering inference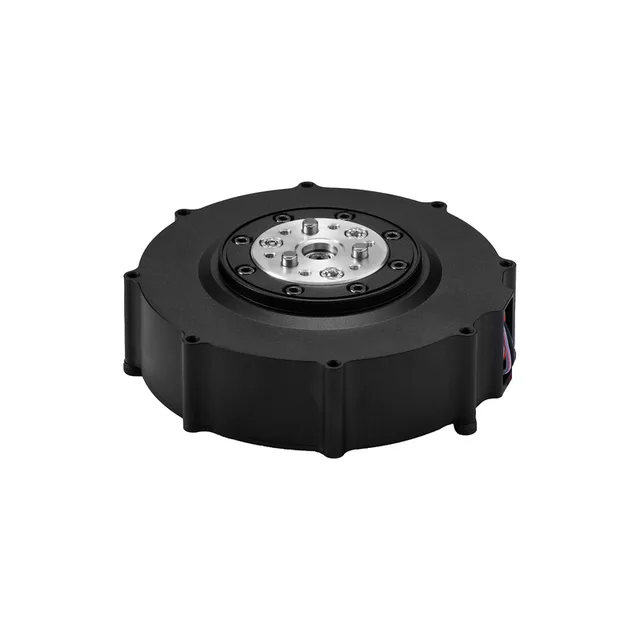
SteadyWin
SteadyWin GIM8108-8 is a Ø92 mm brushless joint motor with an 8:1 steel planetary reducer. With the GDS68 driver at 48 V (12–56 V) it gives 7.5 N·m rated and 22 N·m stall torque, 110 rpm rated and 320 rpm max, 336 W, 1 N·m/A and 15 arcmin backlash. It has a 16-bit encoder plus an optional second encoder, CAN, IP54, and weighs 396 g at Ø92 × 55 mm.
GIM8108-8Development boardFacts about the complete product. Unknown values remain open design questions.
Guidance to help you shortlist. The basis is shown for each recommendation.
quasi-direct-drive actuator: 7.5 N·m rated / 22 N·m peak at 8:1, 320 rpm no-load.
Engineering inferenceNo-load speed, rated performance and stall limits describe different operating points. A stall specification is not a continuous operating rating.
Generated from the datasheet's dimensioned drawing and measured against it. Download the STEP to check fit in your own enclosure.
What the joint can deliver and how the controller talks to it.
| Connector | Type |
|---|---|
| power_can | XT30 (2+2) power + CAN connector on the GDS68 (SDC104) driver |
Rated torque is continuous; peak torque is short-duration. Values with two figures (e.g. 24/48 V) are per supply voltage.
No-load, rated-load and stall figures retain their separate test conditions.
Stall torque and current are not continuous ratings. Check the duty cycle and starting load when choosing the driver and power supply.
Product operating conditions, chip ambient ratings, package case limits and junction maxima remain separate.
Reported product dimensions may exclude protruding components. Unknown height does not establish a complete clearance envelope.
Attached generated geometry is an approximate envelope. A generated outline does not establish an electrically verified PCB footprint.
| ID / type | Pins | Pitch | Notes |
|---|---|---|---|
| power_canXT30 (2+2) power + CAN connector on the GDS68 (SDC104) driver | 4 | Unknown | — |
Every available field, including details beyond the summaries. Null means the value has not been established.
US / USD is the target market. Observed price and stock are separate from a delivery quote.
US · USD
This observation is stale or has no verified check time. Recheck with the supplier.
Visit supplier (opens in a new tab)Delivery depends on quantity, postal code and shipping method. A dispatch statement such as “ship today” is not an arrival estimate.
Each source keeps its own verification status. Confirm the part revision and file contents before using it in a design.
Manufacturer reference
Unverified reference
inspected: wide black Ø92 pancake body with bolt bosses around the rim, silver output flange with dowel pins and centre bore, leads exiting the side. Retailer image → unverified.
Generated asset
cad_check passed
Generated envelope geometry may also exist for this record. It does not replace manufacturer CAD or a verified electrical land pattern.
Document provenance, retrieval dates and the field groups supported by each source.
Supports: spec.constraints.electrical.supply_voltage_nominal_v, spec.constraints.thermal.operating_temp_max_c, spec.constraints.thermal.operating_temp_min_c, spec.geometry.body_diameter_mm, spec.geometry.body_length_mm, spec.geometry.cad.bbox.height_mm, spec.geometry.cad.bbox.length_mm, spec.geometry.cad.bbox.width_mm, spec.geometry.cad.envelope_complete, spec.geometry.cad.mesh_path, spec.geometry.cad.step_path, spec.geometry.cad.verification, spec.geometry.dimensions.height_mm, spec.geometry.dimensions.length_mm, spec.geometry.dimensions.width_mm, spec.geometry.other.weight_g, spec.provides.actuator_type, spec.provides.backlash_deg, spec.provides.control_interface, spec.provides.encoder, spec.provides.encoder_bits, spec.provides.features, spec.provides.gear_ratio, spec.provides.gear_type, spec.provides.integrated_driver, spec.provides.kt_nm_per_a, spec.provides.kv_rpm_per_v, spec.provides.motor_type, spec.provides.no_load_speed_rpm, spec.provides.other.pole_pairs, spec.provides.other.rated_power_w, spec.provides.peak_torque_nm, spec.provides.rated_speed_rpm, spec.provides.rated_torque_nm, spec.usage.connectors, spec.usage.pinout_complete, spec.usage.requirements.other.peak_current_a, spec.usage.requirements.rated_current_a, spec.usage.requirements.rated_voltage_v
sha256 5627bfae000d32eb91e11022703308db022db79ae520027daf5d977e3ab9c80d
Supports: offers
From $85 at www.roboticscenter.ai. Prices are observed unit prices before tax and shipping.
92 × 92 × 55 mm. A STEP model is available for enclosure fit checks.
Every value in this record is traced to a source — 2 documents including the board and chip datasheets — with the page and table cited per value. Unknowns are left explicit, never guessed.